What Is an MCB Assembly Robot and How Does It Work?

An MCB Assembly Robot is an industrial system designed to build miniature circuit breakers with speed, accuracy, and repeatability. MCBs protect electrical circuits from overloads and short circuits. Their internal parts are small, delicate, and difficult to handle consistently by hand.

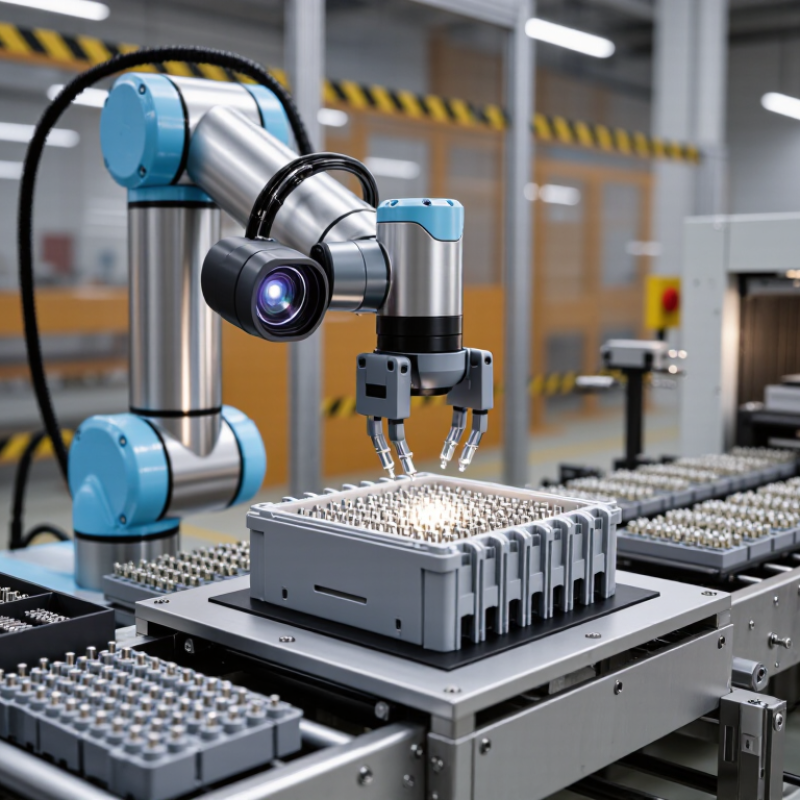
The machine usually begins with bowl feeders or tray systems. These devices separate terminals, springs, contacts, housings, and trip mechanisms. Robotic grippers then position each component inside a fixture. Vision cameras check orientation and surface condition. Servo-driven tools apply controlled pressure or torque during assembly. The completed breaker may pass through electrical tests, insulation checks, and mechanical trip tests before packaging.

Dr. Thomas Pilz, a recognized automation and machine-safety specialist, stated, “Safety is not a product, but a process.” That principle matters here. A reliable Mcb Assembly Robot needs guarded work areas, emergency stops, validated software, and regular maintenance. It also requires accurate data records for every production batch.

Automation is not magic. A robot can repeat a mistake perfectly if sensors or settings are wrong. Dust, vibration, worn grippers, and poorly aligned parts can reduce quality. Engineers must therefore review cycle data and inspect failed units instead of trusting impressive production numbers. A practical system balances speed with controlled verification. When properly designed, it can reduce manual strain, improve assembly consistency, and reveal problems earlier. Yet every factory has different components and risks, so one standard machine will not suit every MCB production line.
What Is an MCB Assembly Robot and How Does It Work?

MCB Assembly Robots: Definition, Purpose, and Industrial Role

An MCB assembly robot is an automated system designed to build miniature circuit breakers with consistent speed and accuracy. It handles tasks such as component feeding, spring placement, contact installation, screw fastening, and electrical testing. Sensors check each part before assembly continues. A rejected unit moves to a separate tray.

Its purpose is practical. MCB production involves small parts, repetitive motions, and strict timing. A robot can maintain stable insertion force and record production data for traceability. According to the International Federation of Robotics’ World Robotics 2024 report, 541,302 industrial robots were installed worldwide in 2023. This growth reflects wider factory demand for repeatable automation, including electrical protection equipment.

The industrial role extends beyond assembly. Robots can connect vision inspection, torque monitoring, insulation testing, and automatic packaging in one line. Operators then supervise process quality, replenish feeders, and investigate unusual results. The International Electrotechnical Commission’s standards for low-voltage circuit breakers emphasize performance and testing requirements, making verification essential.

Automation is not flawless. That assumption can fail. Poorly aligned feeders may create hidden defects, while excessive speed can increase jams or contact damage. In practice, experienced engineers adjust grippers, test limits, and maintenance intervals using real production data. A reliable MCB assembly robot is therefore more than a fast machine. It is a controlled manufacturing system, shaped by mechanical design, software logic, electrical testing, and human judgment.

Core Components and Mechanical Structure of an MCB Assembly Robot

What Is an MCB Assembly Robot and How Does It Work?

An MCB assembly robot combines precision mechanics, electrical control, and inspection technology. Its frame usually has a rigid steel base, vertical columns, linear slides, and servo-driven rotary axes. These parts keep the assembly head stable while it handles miniature circuit breakers. The structure must resist vibration. Even small movement can misalign a terminal or spring.

A typical system includes vibratory feeders, pick-and-place modules, electric screwdrivers, force sensors, and a vision camera. The feeder separates contacts, housings, toggles, and trip mechanisms. A servo gripper then positions each part inside the MCB housing. Force feedback helps detect incomplete insertion. The controller synchronizes motion, torque, timing, and inspection results. According to the International Federation of Robotics, 541,302 industrial robots were installed worldwide in 2023, showing the scale of modern factory automation. However, robot quantity does not guarantee assembly quality.

Mechanical design remains the practical foundation. Guide rails need accurate alignment, while tool changers allow quick fixture adjustment. Sensors verify part presence before the next motion begins. A guarded cell also limits access during operation, following recognized machinery-safety practices. Real production floors are less tidy. Dust, dimensional variation, and worn grippers can interrupt a perfect sequence. A rigid frame may still fail when maintenance access is poor. Engineers should review cycle-time reports, rejected units, and operator feedback before changing the structure. Small improvements often come from better fixtures, not faster motors.

What Is an MCB Assembly Robot and How Does It Work? — Core Components and Mechanical Structure

Component Typical Mechanical Structure How It Works Role in MCB Assembly
Machine frame and base Rigid steel or aluminum structure with mounting plates, guards, and adjustable feet. Supports stations and moving mechanisms while limiting vibration and maintaining alignment. Provides the stable foundation needed for repeatable positioning and assembly.
Part-feeding system May include vibratory bowl feeders, linear tracks, magazines, hoppers, or trays. Separates and presents components in a consistent orientation for pickup or insertion. Supplies items such as molded housings, contacts, springs, terminals, and mechanisms.
Indexing or transfer unit Rotary indexing table, linear transfer track, pallet conveyor, or servo-driven shuttle. Moves a workpiece between stations, often stopping at programmed positions for processing. Coordinates the assembly sequence and keeps parts aligned during each operation.
Pick-and-place mechanism Cartesian slide, pneumatic actuator, servo axis, or compact robotic arm fitted with a gripper. Uses a mechanical or vacuum gripper to pick components and place them at designated locations. Loads parts into fixtures and transfers components between feeding and assembly stations.
Assembly fixtures and nests Custom-machined pockets, locating pins, clamps, and replaceable tooling inserts. Locates and restrains the workpiece so components can be inserted or fastened accurately. Controls part position and supports consistent assembly across production cycles.
Insertion and pressing unit Guided pneumatic or servo-electric press with a punch, insertion tool, or force sensor. Applies controlled linear motion to seat contacts, terminals, or other press-fit components. Creates mechanical retention while helping prevent incomplete insertion or part damage.
Screwdriving or fastening unit Automatic screwdriver spindle with a screw feeder, bit, and torque or angle monitoring. Feeds and tightens fasteners according to defined process settings. Secures components or covers where the MCB design uses screws.
Sensor and vision system Photoelectric sensors, proximity switches, cameras, and, where needed, force or position sensors. Detects part presence, orientation, position, and selected assembly features; sends signals to the controller. Supports process checks, part verification, and fault detection before the next operation.
Control system Industrial controller, operator panel, motor drives, input/output modules, and machine software. Runs the sequence, coordinates actuators, reads sensors, and displays machine status and alarms. Synchronizes feeding, transfer, assembly, inspection, and discharge operations.
Safety equipment Fixed guards, interlocked doors, emergency-stop devices, and safety-rated control components. Stops or restricts hazardous motion when a guard is opened or an emergency stop is activated. Helps protect operators during setup, operation, and maintenance.
Inspection and discharge station Test fixtures, sensors, reject diverters, and a conveyor or collection tray. Checks selected assembly conditions and routes accepted or rejected units to separate outputs. Provides a final process check and organizes completed MCBs for the next production step.

Working principle: An MCB assembly robot combines part feeding, workpiece positioning, automated assembly actions, sensing, and control. The exact station layout and assembly sequence depend on the circuit-breaker design and production requirements.

How an MCB Assembly Robot Performs Each Assembly Step

An MCB assembly robot builds miniature circuit breakers through a controlled sequence of precise movements. Each step protects the device’s mechanical and electrical performance. The process begins when feeders separate housings, toggles, terminals, springs, and internal contacts. Sensors check part presence before the robot lifts each component. Small misalignment matters. A camera may inspect shape, orientation, and surface defects before assembly continues.

The robot places the internal trip mechanism inside the housing with measured force. It then positions the contact bridge and spring, which require careful alignment. A gripper holds the spring while another tool seats the contact assembly. If the spring twists, the breaker may fail during later testing. The system can pause, remove the part, and request inspection instead of forcing the cycle. This safeguard reduces hidden assembly errors.

After the mechanism is installed, the robot fits the cover and secures the enclosure with screws or controlled fastening. Torque monitoring confirms that each fastener reaches the required range. Excessive torque can damage plastic threads. Insufficient torque can create movement or poor protection. Electrical stations then check continuity, insulation, switching action, and trip response. Vision cameras verify markings and final shape. A rejected unit moves to a separate tray for analysis, while accepted units receive production data for traceability. Automation improves consistency, but it is not infallible. Dust, worn tooling, or a poorly calibrated sensor can still disturb the process. Operators must review these weak points regularly.

Control Systems, Sensors, and Quality Inspection Functions

An MCB assembly robot builds miniature circuit breakers through coordinated feeding, fastening, testing, and handling. Its control system synchronizes servo motors, pneumatic tools, feeders, and safety interlocks. It receives position data from encoders and timing signals from the production line. A programmable controller then adjusts movement within milliseconds.

Sensors provide the robot’s practical awareness. Vision cameras check terminal orientation, housing color, and missing components. Force sensors detect abnormal resistance during screwdriving or contact insertion. Photoelectric sensors confirm whether parts reach each station.

The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, showing how automated control is becoming standard in high-volume manufacturing.

Still, more automation does not guarantee better accuracy.

Quality inspection runs during assembly, not only at the end. Electrical testers measure continuity, insulation resistance, and trip response. Vision software compares each breaker with defined dimensional patterns. Traceability data can record torque, test results, sensor alarms, and cycle time for every unit.

Industry quality studies from the International Organization for Standardization emphasize process monitoring and documented control as foundations of reliable production. In practice, false rejects remain a weakness. Dust, glare, or a slightly misaligned component can confuse a camera.

Engineers must review rejected parts manually and refine inspection thresholds. A clever system still needs careful human judgment.

Benefits, Applications, and Maintenance Requirements

What Is an MCB Assembly Robot and How Does It Work?

An MCB assembly robot automates the placement, fastening, testing, and inspection of miniature circuit breakers. A typical cell uses a feeder, robotic arm, torque tool, vision camera, and electrical tester. The robot collects molded parts, positions metal contacts, and checks each assembly against programmed tolerances. Sensors can detect missing springs, incorrect terminal positions, or loose screws before packaging.

The benefits are practical. Automated handling improves repeatability and reduces hand injuries caused by repetitive motions. It also supports steady production during demand peaks. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. This figure shows broad industrial confidence, but it does not guarantee every robotic cell will deliver savings. Poor part feeding can still stop production.

MCB assembly robots serve electrical equipment factories, control-panel production, and high-volume component lines. Their value is clearest when products have stable designs and measurable inspection points. Maintenance needs daily cleaning around feeders and sensors. Operators should inspect grippers, cables, pneumatic lines, and torque tools each shift. Calibration should follow the equipment maker’s schedule, with documented test results. Vision lenses need careful cleaning. Small dust matters.

Software backups and spare sensors reduce recovery time. Preventive maintenance is essential. Still, teams often underestimate changeover work when several MCB designs share one line. Production data, failure codes, and maintenance history should be reviewed together. Industry reports provide useful benchmarks, yet each factory needs its own time-study evidence before expanding automation.

What Is an MCB Assembly Robot and How Does It Work?

An MCB assembly robot automatically feeds, positions, fastens, inspects, and tests miniature circuit-breaker components. The chart shows the theoretical hourly output calculated from different cycle times using the formula: 3,600 seconds ÷ cycle time.

Benefits and maintenance: Shorter cycle times can increase theoretical throughput and improve production consistency. Actual output will be lower after accounting for changeovers, material replenishment, stoppages, inspection rejects, and planned maintenance. Typical maintenance activities include cleaning grippers and fixtures, checking sensors and fasteners, lubricating moving parts where specified, verifying safety devices, and periodically calibrating inspection equipment.

Select Electrical Logo
Since 1988

Select Electrical Ltd. © Copyright 1988-2025