Choosing the right electric motor starter is not a minor purchasing decision. It affects motor protection, starting performance, energy use, and equipment life. A starter that looks suitable on paper may still fail in a hot workshop, a dusty plant, or a system with frequent starts.
Electricians and maintenance engineers usually examine the motor’s voltage, full-load current, phase, starting method, and duty cycle. They also check enclosure ratings, overload protection, control voltage, and available space inside the panel. Manufacturer instructions and recognized electrical standards provide essential guidance. However, field conditions often reveal details that product brochures overlook. Cable length, ambient temperature, mechanical load, and voltage fluctuations can change the final choice.
Small details matter.
This guide presents seven practical tips for selecting an electric motor starter with greater confidence. It considers common options, including direct-on-line, reduced-voltage, and electronic starters. Each option has different effects on inrush current, torque, wiring complexity, and maintenance. The goal is not to promote the most expensive solution. It is to match the starter with the motor and its working environment.
Even experienced technicians can make an incorrect assumption. A starter may protect against overload but still lack suitable short-circuit coordination. Another may reduce starting current but provide insufficient torque for a loaded conveyor. These mistakes deserve careful reflection. Reviewing the motor nameplate, installation conditions, and manufacturer data together creates a more reliable decision. When uncertainty remains, a qualified professional should verify the selection before installation.
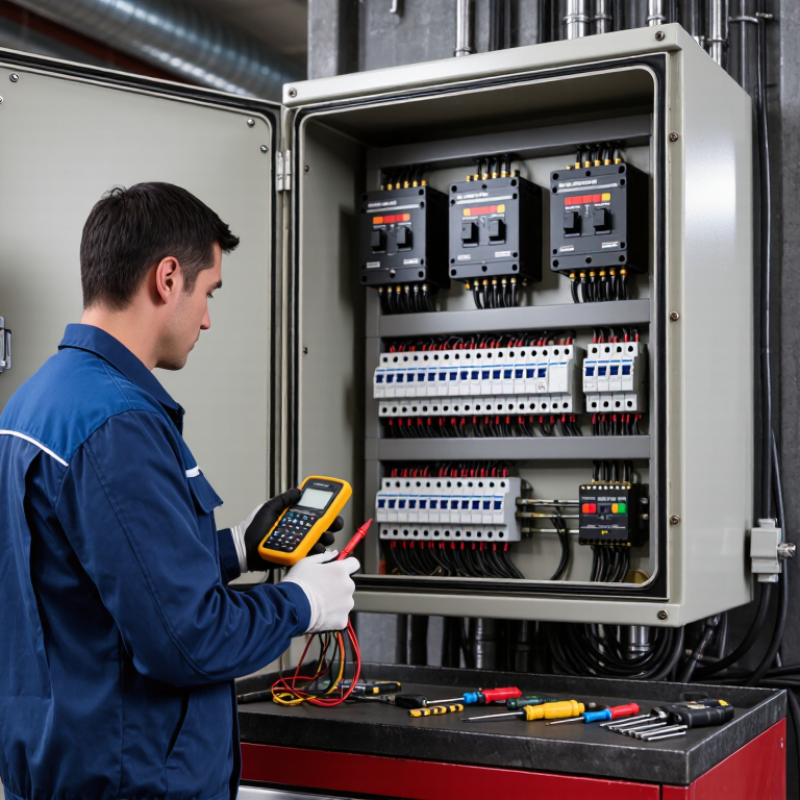
Choosing an electric motor starter begins with the motor’s real load, not its advertised power. Under IEC 60947-4-1, AC-3 applies mainly to squirrel-cage motors. It covers starting and switching off after the motor reaches speed. That detail matters. AC-3 is not a universal rating for every motor duty.
Read the nameplate voltage, rated current, power, frequency, and service conditions. Match the starter’s operational current, Ie, at the actual utilization voltage. Check whether the machine starts loaded, such as a full conveyor, or unloaded, like a fan. Record starts per hour and acceleration time. Note reversing or inching operations. Small details matter. Frequent jogging or plugging may indicate AC-4 behavior, requiring a different assessment. Ambient heat, enclosure temperature, altitude, and cable conditions can reduce practical margin.
Coordinate the contactor, overload relay, and short-circuit protective device as one system. Set overload protection from motor data and applicable requirements, not power alone. Confirm the starter tolerates starting current without nuisance tripping. In field reviews, engineers sometimes select by horsepower and stop there. I have made that assumption too. It can hide severe starting duty. Verify AC-3 test conditions, duty limits, and coordination data. If the load changes seasonally, size for the hardest normal start and document the reasoning.
Selecting an electric motor starter begins with understanding starting current. During acceleration, many motors draw six to eight times their full-load amps. That surge can cause voltage dips, nuisance trips, or overheated cables. Use measured data.
A direct-on-line starter suits smaller motors with a stiff power supply. Its simplicity reduces maintenance and installation effort. Yet, it applies full starting current immediately. If the driven load needs a longer acceleration time, this choice may stress the motor and mechanical system.
In field commissioning, I have seen nameplate values differ from actual behavior. The motor, cable length, supply capacity, and load all affect current demand. Measure where possible. A reduced-voltage starter can limit the initial surge, while a soft starter provides smoother acceleration. A variable-frequency drive offers stronger control when speed adjustment matters. Choose carefully.
Do not size the starter from motor horsepower alone. Check full-load amps, locked-rotor current, starting duration, and switching frequency. Confirm that protective devices tolerate the brief inrush without sacrificing fault protection. Document the readings. Recheck them after installation. Real conditions often challenge the original calculation.
Size the contactor by motor horsepower, voltage, and duty category, not FLA alone.
Tip 1: Verify the motor nameplate. Record voltage, phase, horsepower, service factor, and full-load amperes.
Tip 2: Use NEC Table 430.250 when checking three-phase motor values. The table uses standardized full-load currents, which may differ from the nameplate FLA.
Tip 3: Select a contactor rated for the motor’s utilization duty. Starting current can briefly reach several times rated current.
Tip 4: Size the overload relay from the motor nameplate current and NEC 430.32. For many continuous-duty motors, the permitted setting begins at 115% or 125%, depending on service factor and temperature-rise conditions. Do not automatically choose the largest setting.
Tip 5: Confirm the relay’s adjustment range includes the actual FLA. A relay that barely reaches the target may be difficult to calibrate accurately.
Tip 6: Check ambient temperature, enclosure heat, starts per hour, and acceleration time. These details can expose weaknesses in an otherwise correct selection. Test it.
The U.S. Department of Energy’s Motor Systems Market Assessment (2021) reports that motor-driven systems consume more than half of industrial electricity in the United States. Small protection errors can therefore create significant operating losses.
Tip 7: Compare the starter with the disconnect, short-circuit protection, control voltage, and grounding method. NFPA 70, 2023 edition, including Articles 430.6 and 430.32, should guide the final review. Field measurements still matter. Nameplate data may be incomplete, and assuming ideal conditions is a mistake worth revisiting.
Choosing an electric motor starter begins with the permitted voltage drop, not just purchase price. Measure the supply impedance, transformer capacity, cable length, and motor locked-rotor current. A DOL starter is simple and reliable, but its starting current may reach five to eight times full-load current. On a weak feeder, lights can flicker and protection may trip. Confirm the utility or project limit; 3% and 5% values are common references, not universal rules.
Star-delta starting reduces line current to roughly one-third of DOL during the initial connection. Starting torque also falls to about one-third. That matters for conveyors, pumps, and compressors that resist movement. The transition can create a current spike. Check the motor’s terminals, timer setting, and load acceleration time. A poorly timed changeover may produce more disturbance than expected. It happens.
A soft starter ramps voltage and can limit current more smoothly. Set its current limit, ramp time, and initial torque from measured load behavior, not default values. Review the manufacturer’s thermal limits and the motor’s permissible starts per hour. Compare the calculated voltage drop at the worst operating point, including neighboring loads. Record readings during a cold start and a loaded start. I once trusted a no-load test too much; the loaded conveyor exposed a much larger dip. Leave engineering margin, because field conditions rarely match the drawing. Use DOL where the network is stiff, star-delta where reduced current is adequate, and soft starting where controlled acceleration protects both the feeder and driven equipment.
Typical starting-current values are shown as multiples of motor full-load current. The illustrative voltage-drop values assume a feeder voltage drop of 2% at full-load current; actual results depend on cable impedance, transformer capacity, motor size, and supply conditions.
Direct-on-line starters commonly draw about 5–8 times full-load current, which can produce significant voltage sag. Star-delta starting typically reduces line current to about one-third of DOL starting current, while soft starters allow the current limit to be adjusted, commonly around 2–4 times full-load current. A 10% starting-voltage-drop line is shown as an illustrative design criterion, not a universal code limit.
7 Tips for Choosing an Electric Motor Starter
Check the motor’s voltage, full-load current, starting method, and duty cycle before selecting a starter. Confirm overload protection matches the motor, not merely the starter’s maximum rating. Verify short-circuit protection and coordination with the upstream disconnect. A crowded control cabinet can hide poor heat management. Leave practical space for wiring, inspection, and future testing.
Select the enclosure for the actual environment. An IP rating addresses dust and water ingress, while NEMA enclosure types use different testing and application criteria. Do not treat IP65 and a NEMA rating as automatic equivalents. For a washdown area, inspect door seals, cable entries, drainage, and mounting orientation. Small gaps around glands can defeat an otherwise suitable enclosure. I once focused on the listed rating and overlooked condensation inside the cabinet. That decision needed rethinking.
Use IEC requirements when the project specifies IEC equipment and apply NEMA guidance when that system governs selection. Check the relevant motor-starter standard, such as IEC 60947-4-1, alongside local electrical rules. NEMA sizing and application practices may emphasize different design assumptions. Ask whether the starter supports the motor’s locked-rotor current and switching frequency. Test the overload setting under realistic ambient conditions. Document the selected rating, protection device, enclosure type, and inspection results. Keep the record clear. A certified component still fails when installed carelessly.
| Selection Dimension | What to Verify | Typical Data or Rating | Why It Matters | Applicable Standard or Reference | Recommended Selection Check |
|---|---|---|---|---|---|
| 1. Motor Voltage and Phase | Compare the starter’s coil, switching, and control-circuit ratings with the motor nameplate and supply system. | Common systems include single-phase or three-phase AC supplies at 50 Hz or 60 Hz. The starter must be rated for the actual line voltage. | An incorrect voltage rating can prevent reliable operation, cause contactor damage, or create an unsafe control condition. | IEC 60947-4-1; applicable local electrical codes. | Confirm line voltage, frequency, number of phases, motor connection, and control-circuit voltage before selecting the starter. |
| 2. Motor Current and Utilization Category | Check motor full-load current, starting current, duty cycle, and switching frequency. | For IEC selection, AC-3 is commonly used for squirrel-cage motor starting and switching during normal operation. AC-4 applies to demanding inching, plugging, or frequent reversing duties. | A starter suitable for ordinary starting may wear rapidly if it is used for jogging, plugging, or frequent reversals. | IEC 60947-4-1 utilization categories AC-3 and AC-4; NEMA ICS 2 for industrial control equipment. | Select the contactor or starter by motor current and duty category, not by horsepower alone. |
| 3. Overload Protection | Verify adjustable overload range, trip class, phase-loss sensitivity, and compatibility with the motor’s service conditions. | IEC overload trip classes commonly include Class 10A, Class 10, Class 20, and Class 30. The setting should be based on the motor nameplate current and applicable code requirements. | Overload protection limits prolonged overcurrent and helps reduce winding overheating. It does not replace short-circuit protection. | IEC 60947-4-1; motor protection requirements may also be governed by national electrical codes. | Set the overload relay according to the motor nameplate and installation rules. Do not use the overload relay as the sole means of short-circuit protection. |
| 4. Short-Circuit and Fault Protection | Verify the required fuse or circuit-breaker type, interrupting rating, and available short-circuit current. | The starter assembly should have a documented short-circuit current rating or prospective-fault withstand rating appropriate for the installation. | Overload relays respond to sustained overcurrent, while fuses or circuit breakers interrupt high-energy short circuits. | IEC 60947-4-1 coordination requirements; IEC 60947-2 for circuit breakers; applicable national codes. | Check the coordination table or tested combination for the starter, protective device, and motor circuit. Confirm that the interrupting rating exceeds the available fault current. |
| 5. Enclosure and Environmental Protection | Assess dust, water, oil, washdown, corrosion, impact, ambient temperature, and indoor or outdoor installation conditions. |
IP54: limited dust ingress and protection against water splashes. IP55: dust protected and protected against water jets. IP65: dust-tight and protected against water jets. IP66: dust-tight and protected against powerful water jets. IP67: dust-tight and protected against temporary immersion. |
The enclosure rating helps prevent contamination, moisture ingress, and premature failure of the starter and its control components. | IEC 60529 defines IP ratings. IP ratings are not a direct one-to-one replacement for NEMA enclosure types. | Choose the IP rating based on the actual exposure. For outdoor or washdown locations, verify UV resistance, drainage, cable entries, and door-gasket integrity. |
| 6. NEMA Enclosure Classification | Determine whether the installation needs protection from indoor dust, rain, hose-directed water, oil, or corrosion. |
NEMA Type 1: general-purpose indoor protection. NEMA Type 3R: outdoor protection against rain, sleet, and snow. NEMA Type 4: indoor or outdoor protection against hose-directed water and dust. NEMA Type 4X: Type 4 protection with additional corrosion resistance. NEMA Type 12: indoor protection against dust, dirt, and dripping or lightly splashed liquids. |
NEMA classifications describe enclosure construction and environmental protection for equipment used in North American practice. | NEMA 250; verify the exact enclosure construction and intended environment. | Do not infer an exact IP equivalent from a NEMA type. Use the enclosure standard specified by the project, inspector, or local code. |
| 7. Standards, Installation, and Maintenance | Confirm the required certification, wiring method, terminal ratings, ambient temperature limits, clearances, and access for maintenance. | IEC-based projects commonly reference IEC 60947-4-1 for contactors and motor starters, while North American projects may reference NEMA ICS 2 and NEMA 250. | Correct standard alignment supports consistent testing, documentation, installation, and replacement of the motor starter. | IEC 60947-4-1, IEC 60529, NEMA ICS 2, NEMA 250, and applicable national or local electrical codes. | Verify markings, certification documents, terminal torque requirements, conductor size, grounding, emergency-stop integration, and periodic overload-function testing. |
Important: Final starter selection should be based on the motor nameplate, fault-current study, installation environment, applicable electrical code, and the equipment manufacturer’s certified ratings. IP and NEMA enclosure classifications should be treated as separate rating systems unless a documented equivalence is specifically provided.